Getting Started#
Introduction#
This manual describes the basic operation, handling, and maintenance procedures for the quadruped mobile robot Honey Badger 5.0. It is intended for operators, engineers, and service personnel who need to safely prepare, start, control, stop, and inspect the robot.
Before operating the robot, read this manual carefully, especially the safety instructions and emergency stop procedures. The robot contains powerful electric actuators and can move suddenly if enabled incorrectly.
Overview#
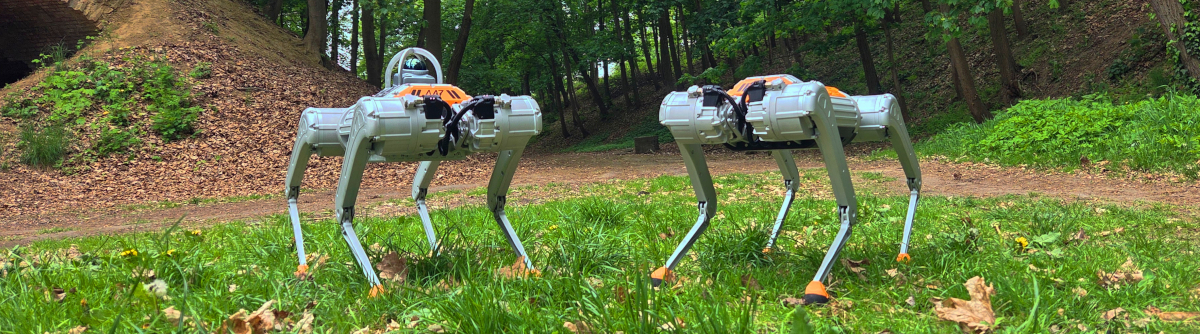
The robot is a four-legged mobile robotic platform designed for research, testing, inspection, and autonomous or remotely controlled operation. It is equipped with electric actuators, onboard computers, a battery power system, sensors, and communication interfaces. The robot can operate in several modes, including idle, standing, walking, teleoperation, and safety/recovery mode. Depending on the installed software and hardware configuration, the robot may support mapping, localization, or autonomous operation.
The main components of the robot are:
quadruped mechanical body,
four articulated legs with electric actuators,
two onboard computers (LPC and APC) — see Platform for roles and network addresses,
battery system,
sensors,
communication interfaces,
operator control interface.
Next steps#
For startup and operation, use the core procedure pages below:
Safety — safety and emergency procedures.
FirstStartup — step-by-step startup checklist.
ControlConsole — Steam Deck control and operator console.
Setup — package contents, network reference, and charging.