Geometry and Frames#
Robot structure#
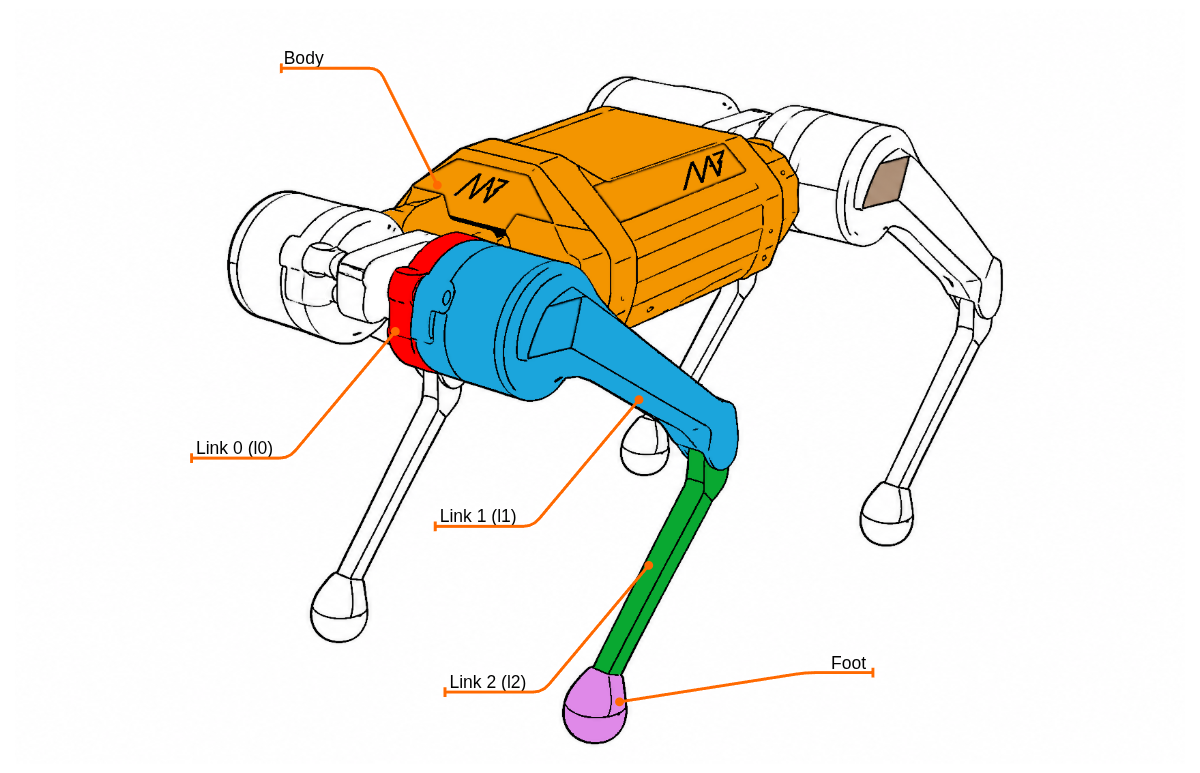
The main robot parts are illustrated below. Use the naming and frame conventions from this page consistently in logs, diagnostics and documentation.
Leg naming#
Abbreviation |
Meaning |
|---|---|
|
Front‑right leg |
|
Front‑left leg |
|
Rear‑left leg |
|
Rear‑right leg |
Local coordinate frame#
The robot uses a right‑hand coordinate system with origin at the chassis center (approximately the center of mass). Axes and rotations are defined as:
X — forward (positive toward the robot front)
Y — left (positive toward the robot left)
Z — up (positive opposite gravity)
Rotations:
Roll — rotation around X
Pitch — rotation around Y
Yaw — rotation around Z
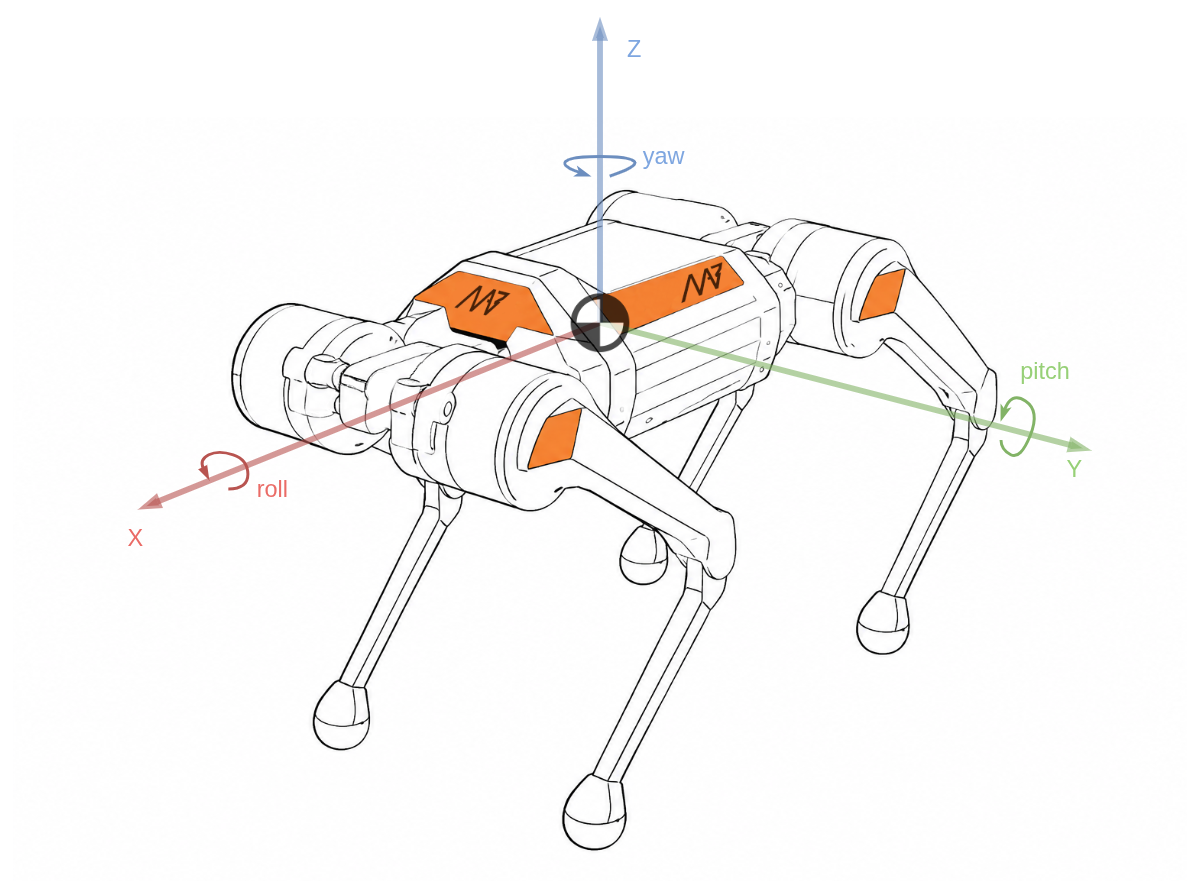
Use these conventions when interpreting TFs, URDF links and joint commands.