NMT Overview [LEGACY]#
Warning
Legacy documentation. This page documents the CANopen implementation shipped with MD firmware 2.5.x. It is kept for users who still run that firmware and is no longer updated.
The CANopen stack has been rewritten for the current firmware and is documented in CANopen. The two object dictionaries are not compatible, so do not read values across from that section.
1. Introduction#
Network Management (NMT) in CANopen is a service that manages the state of nodes (slaves) on the network and ensures smooth operation. The NMT acts like a conductor, coordinating the transitions of nodes between different operating states. During the boot-up, if the motor have correct parameter, the motor should enter automatically into the Operational mode.
2. NMT States#
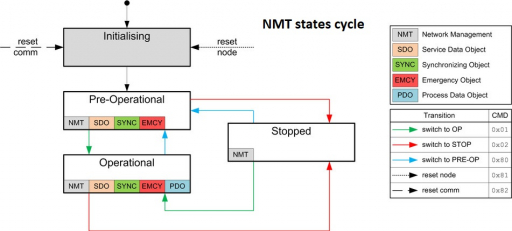
A CANopen node can be in one of the following states:
Initialization – The node starts up and initializes itself.
Pre-Operational – The node can communicate via SDO and receive NMT commands, but PDOs are not active.
Operational – Full communication is enabled (PDO, SDO, SYNC, etc.).
Stopped – The node stops PDO/SDO communication but stays present on the network and can still receive NMT commands.
2.1. Allowed Communication per State#
State |
PDO Communication |
SDO Communication |
NMT Commands Accepted |
|---|---|---|---|
Initialization |
❌ |
❌ |
None |
Pre-Operational |
❌ |
✅ |
Start, Stop, Reset |
Operational |
✅ |
✅ |
Stop, Reset |
Stopped |
❌ |
❌ |
Start, Reset |
3. NMT Message Structure#
An NMT message always uses CAN-ID 0x000 and has a fixed length of 2 bytes:
Byte |
Content |
|---|---|
0 |
NMT Command (Start, Stop, Reset, etc.) |
1 |
Node-ID (0x00 = broadcast to all nodes) |
3.1. NMT Commands#
Command |
Hex Value |
Effect |
|---|---|---|
Start Remote Node |
0x01 |
Switches node to Operational |
Stop Remote Node |
0x02 |
Switches node to Stopped |
Enter Pre-Operational |
0x80 |
Switches node to Pre-Operational |
Reset Node |
0x81 |
Reboots the node and reinitializes application variables |
Reset Communication |
0x82 |
Reboots only the communication stack |
4. Heartbeat#
The Heartbeat is a monitoring mechanism that ensures nodes are alive and functioning.
Each node periodically sends a message containing its current NMT state.
4.1. Heartbeat Message Structure#
Field Content
CAN-ID 0x700 + Node-ID Data 1 byte representing the NMT state of the node
Example:
If node 0x05 is in Operational state, it will send:
CAN-ID = 0x705, Data = 0x05
4.2. Purpose of Heartbeat#
Detect nodes that are offline or unresponsive
Allow the master to monitor network health
Trigger safety actions when communication is lost
5. Conclusion#
NMT services are crucial for:
✅ Setting nodes to the desired state
✅ Monitoring their presence with Heartbeat
✅ Reacting quickly to network failures
Together, NMT and Heartbeat provide reliability and safety in CANopen-based communication systems.